Dealing with a quadcopter throttle problem can be incredibly frustrating, especially when you’re ready to get your drone into the air for a flight. Whether your drone fails to lift off, behaves erratically during takeoff, or suffers from sudden power drops, understanding the root cause is the first step toward a successful repair. By systematically evaluating your hardware, software, and power systems, you can identify why your throttle input isn’t translating into the expected motor performance.
Key Takeaways
- Calibrate your transmitter and flight controller software to ensure throttle endpoints are correctly mapped.
- Check your battery voltage and discharge rates, as failing cells often cause power-drop issues under load.
- Inspect your electronic speed controllers (ESCs) for synchronization errors or outdated firmware.
- Verify that your propellers are properly tightened and not slipping on the motor shafts.
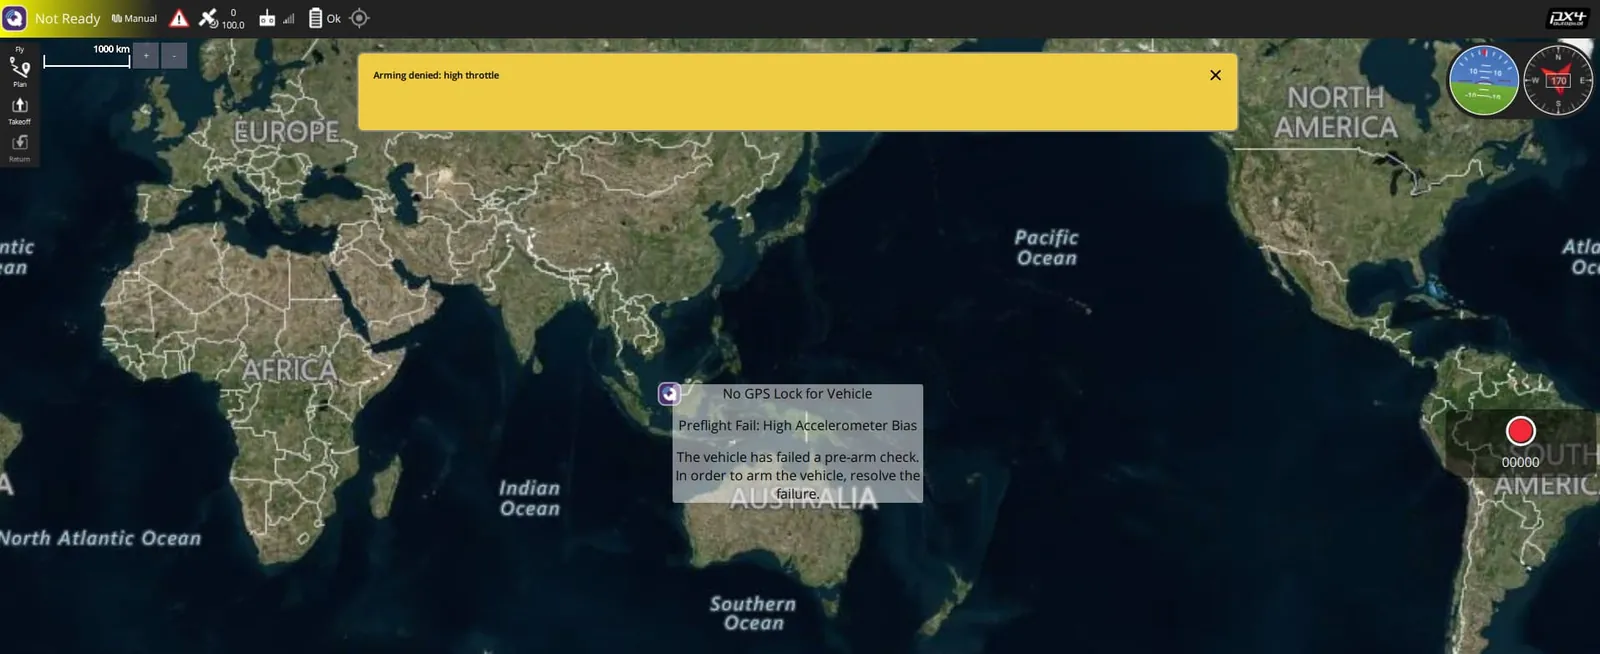
- Ensure that your flight controller’s “arm” sequence is completed correctly before attempting takeoff.
Fixing quadcopter throttle issues
When a drone refuses to respond to throttle inputs, the issue usually stems from a communication breakdown between the transmitter and the receiver, or an internal safety lock within the flight controller. Before opening the chassis, check your transmitter settings.
Many modern flight controllers, such as those running Betaflight, require a specific “arm” command or switch position to be activated before the throttle will engage. If the drone is armed but the motors don’t spin, you likely have a configuration error in the software.
Calibration procedures are essential for resolving mapping issues. If your transmitter is sending a low-throttle signal that the flight controller interprets as “off” or “unarmed,” the motors will remain stationary. Ensure your throttle range is set to the standard 1000us to 2000us range. If the signal falls below the minimum threshold, the flight controller will stay in a safe, idle state to prevent accidental motor engagement.
Is it a battery power issue?
A common quadcopter throttle problem is “voltage sag,” which occurs when the battery can’t provide enough current to satisfy the motors during a rapid throttle increase. If your drone lifts off but loses power immediately when you push the throttle higher, your battery may be damaged or have a low C-rating. High-performance racing drones demand significant discharge rates, and using an inadequate battery can lead to an immediate system brownout.
Voltage sag symptoms include the drone hovering fine at low throttle but falling out of the sky or stuttering when you push the stick forward. Always inspect your battery leads for fraying or loose connections, as resistance in the wiring can cause heat buildup and voltage drops. If you suspect a bad cell, use a digital battery checker to ensure all cells are balanced within 0.05 volts of each other.
| Component | Common Issue | Check Action |
|---|---|---|
| Battery | Voltage Sag | Verify C-rating and cell health |
| ESC | Desync | Update firmware or check timing |
| Transmitter | Dead Zone | Calibrate stick endpoints |
| Flight Controller | Arming Failure | Check arming switch settings |
Understanding the ESC role
Electronic Speed Controllers, or ESCs, act as the brain for each individual motor. If one ESC is malfunctioning, the flight controller may receive conflicting data, leading to erratic throttle behavior or a complete refusal to arm. When an ESC fails to communicate with the flight controller, the motor will usually twitch or remain completely silent during the startup sequence.
Firmware updates for ESCs are often overlooked. Using the Federal Aviation Administration drone safety guidelines as a baseline for safe operation, you should ensure that all hardware modifications remain within legal and technical parameters. If you have replaced a motor or an ESC, you must ensure that the new component is compatible with your existing stack. Mismatched firmware versions can cause communication errors that manifest as unresponsive throttle control during high-intensity maneuvers.
Why are the motors twitching?
If your motors twitch but don’t spin up when you apply throttle, the problem is likely related to the motor-to-ESC connection or the ESC-to-flight controller signal. Inspect the solder joints on your ESC boards. A “cold” solder joint can appear connected but fail to conduct enough electricity to drive the motor under load. This often happens after a hard crash where internal wires are stressed.
Motor timing issues can also cause stuttering. If the ESC settings for motor timing are too aggressive or too conservative for your specific motor type, the motor will struggle to sync. Most modern ESCs allow for auto-timing, which solves this issue. If you’re using older hardware, you may need to manually adjust the timing settings through the ESC configuration software to match the motor’s pole count.
Propeller and motor inspection
Never underestimate the impact of mechanical resistance. If a motor bearing is damaged, the motor will draw excessive current to overcome the friction, causing the ESC to trigger a thermal shutdown or a safety cut-off. Spin each motor by hand while the battery is disconnected; they should feel smooth and silent. If you feel grinding or significant resistance, the bearing is likely contaminated with dust or damaged from a crash.
Propeller slippage is another mechanical culprit. If the prop nut is loose, the motor shaft will spin freely while the propeller barely moves, making it feel like the drone has no throttle response. Always check that your propeller nuts are tightened securely and that the propellers are mounted in the correct orientation. A prop installed upside down will still spin, but it will provide almost zero lift, leading to a drone that refuses to leave the ground.
Advanced software configuration
If you have verified all hardware connections, it’s time to look at the flight controller’s software settings. Most drones use software like Betaflight, INAV, or ArduPilot to manage flight dynamics. Within these programs, you can view the “Receiver” tab to see real-time stick inputs. If your throttle stick movement doesn’t move the bar on the screen, your transmitter and receiver aren’t bound correctly.
Channel mapping is a frequent point of confusion for new pilots. If your transmitter is set to AETR (Aileron, Elevator, Throttle, Rudder) but your software expects TAER, your throttle input might be controlling a different function entirely. Always ensure your channel map matches your transmitter’s output configuration. If the throttle bar moves correctly in the software but the motors don’t spin, check your “Modes” tab to ensure you haven’t assigned the throttle to a restricted switch.
Is my transmitter broken?
Sometimes the quadcopter throttle problem isn’t in the drone at all, but in the transmitter hardware. Potentiometers inside the transmitter sticks can wear out over time, leading to “jittery” signals or dead zones where the transmitter fails to send a value to the receiver. If you see the throttle bar in your flight software jumping around while the stick is held steady, your gimbal is likely failing.
Transmitter maintenance involves cleaning the stick gimbals with compressed air to remove debris. If the issue persists, you may need to open the transmitter and inspect the wiring to the potentiometer. In some cases, a simple recalibration within the transmitter’s internal menu is enough to fix the center-point drift. If the stick data remains erratic after calibration, you may need to replace the gimbal unit entirely.
How to test for signal loss
A “failsafe” event occurs when the receiver loses signal from the transmitter, causing the drone to cut the throttle to prevent a fly-away. If your drone suddenly loses power mid-flight, check your antenna placement. Antennas should be mounted in a “V” shape or at 90-degree angles to each other to maximize signal reception. If your antennas are touching the carbon fiber frame, the signal will be shielded and significantly weakened.
Failsafe settings are critical for safety. You can test your failsafe by turning off your transmitter while the drone is on the ground with the propellers removed. If the motors don’t stop immediately, your failsafe isn’t configured correctly. Never fly a drone that doesn’t have a properly tested failsafe, as it represents a significant safety risk to people and property in the vicinity.
| Step | Action | Tools Required |
|---|---|---|
| 1 | Prop Removal | None |
| 2 | Software Check | USB Cable, PC |
| 3 | Battery Test | Battery Checker |
| 4 | Motor Inspection | Hex Drivers |
| 5 | Signal Check | Transmitter, Receiver |
Safety and maintenance protocols
Warning: Never attempt to troubleshoot a drone with the propellers attached. Even a small drone can cause significant injury if the motors engage unexpectedly. Always remove the propellers before plugging in a battery for software testing or motor calibration. This is the single most important rule in drone maintenance.
Pro Tip: If you’re unsure about the state of your electronics, use a “smoke stopper” device when first powering up the drone after a repair. This is a simple current-limiting tool that prevents a short circuit from frying your entire flight controller stack. It’s an inexpensive investment that can save you hundreds of dollars in replacement parts.
Frequently Asked Questions
Why do my motors beep but not spin?
Beeping usually indicates that the ESCs are receiving power but aren’t receiving a valid signal from the flight controller. This often happens if the flight controller isn’t armed or if the throttle signal isn’t reaching the ESCs. Verify your arming switch and ensure that your flight controller isn’t in a “pre-arm” state that prevents motor activation.
Can a loose wire cause throttle issues?
Yes, a loose wire between the flight controller and the ESC will cause intermittent throttle response or complete motor failure. Because drones vibrate significantly during flight, even a slightly loose solder joint can disconnect. Always check your wiring harnesses and solder points for signs of fatigue or oxidation, especially if the drone has experienced a recent hard landing or crash.
How do I fix a throttle that only works at 100%?
This usually indicates an issue with the throttle range calibration. If your transmitter is sending a signal that the ESC interprets as a calibration command, the ESC may ignore the throttle input until it reaches its maximum range. Re-calibrate your ESCs through your flight controller software to ensure they recognize the full range of your transmitter’s throttle stick movement.
Does the flight mode affect throttle?
Yes, certain flight modes, such as “Angle” or “Horizon” mode, limit the drone’s tilt and can affect how the flight controller manages throttle for altitude hold. If you’re in a self-leveling mode, the drone may struggle to provide full power if it thinks it has reached a specific tilt limit. Switching to “Acro” or “Manual” mode can help you determine if the issue is software-based.
Should I replace my ESC or the motor?
If only one motor is failing to spin, try swapping it with a motor that’s working. If the problem moves to the new location, the motor is likely damaged. If the problem stays at the original location, the ESC is the culprit. This “swap test” is the most reliable way to isolate hardware failures without buying unnecessary replacement parts.
Conclusion
Properly identifying the source of your throttle issues ensures you can return to the air safely and confidently. Start by performing a full software check to rule out configuration errors, then move to physical inspections of your motors and ESCs. If the problem persists, systematic component swapping will help you pinpoint the exact piece of hardware requiring replacement. Keep your firmware updated and maintain your batteries to prevent future incidents.